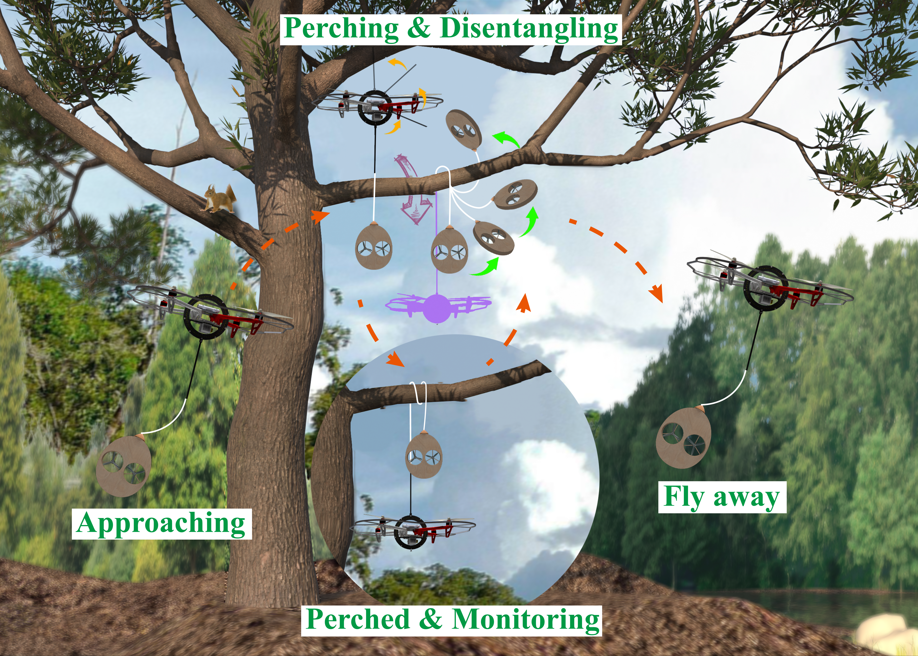
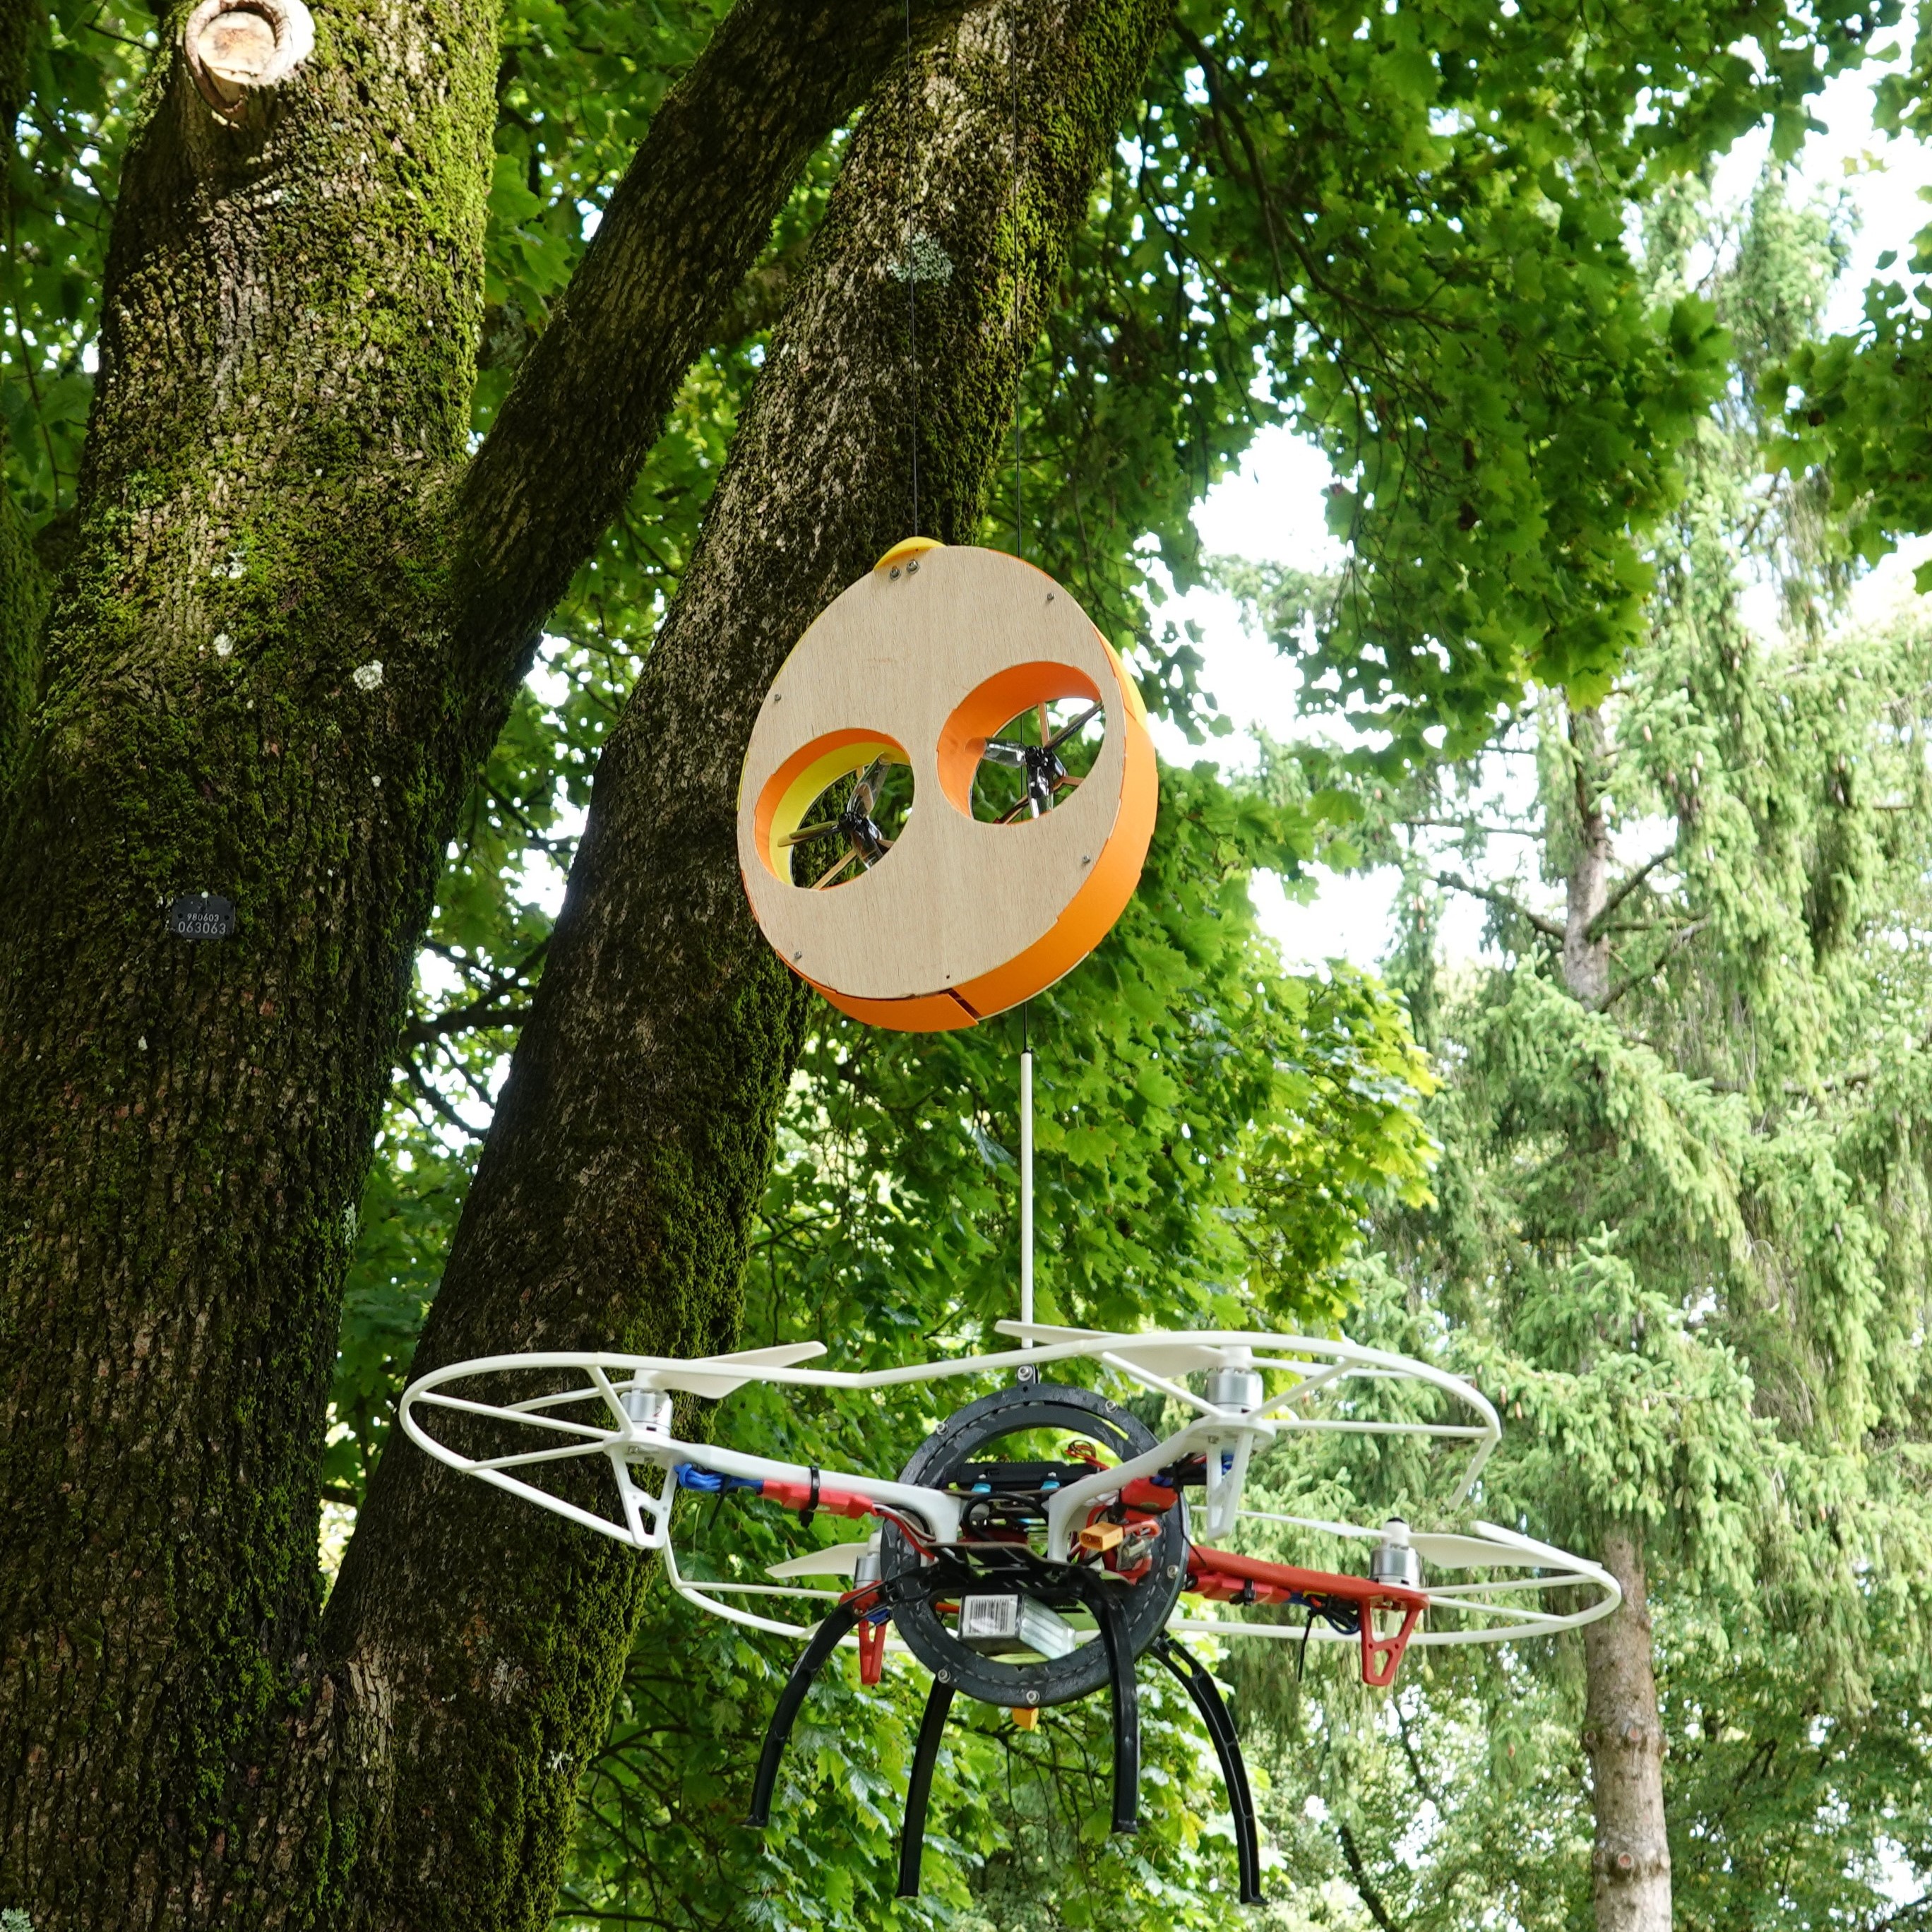
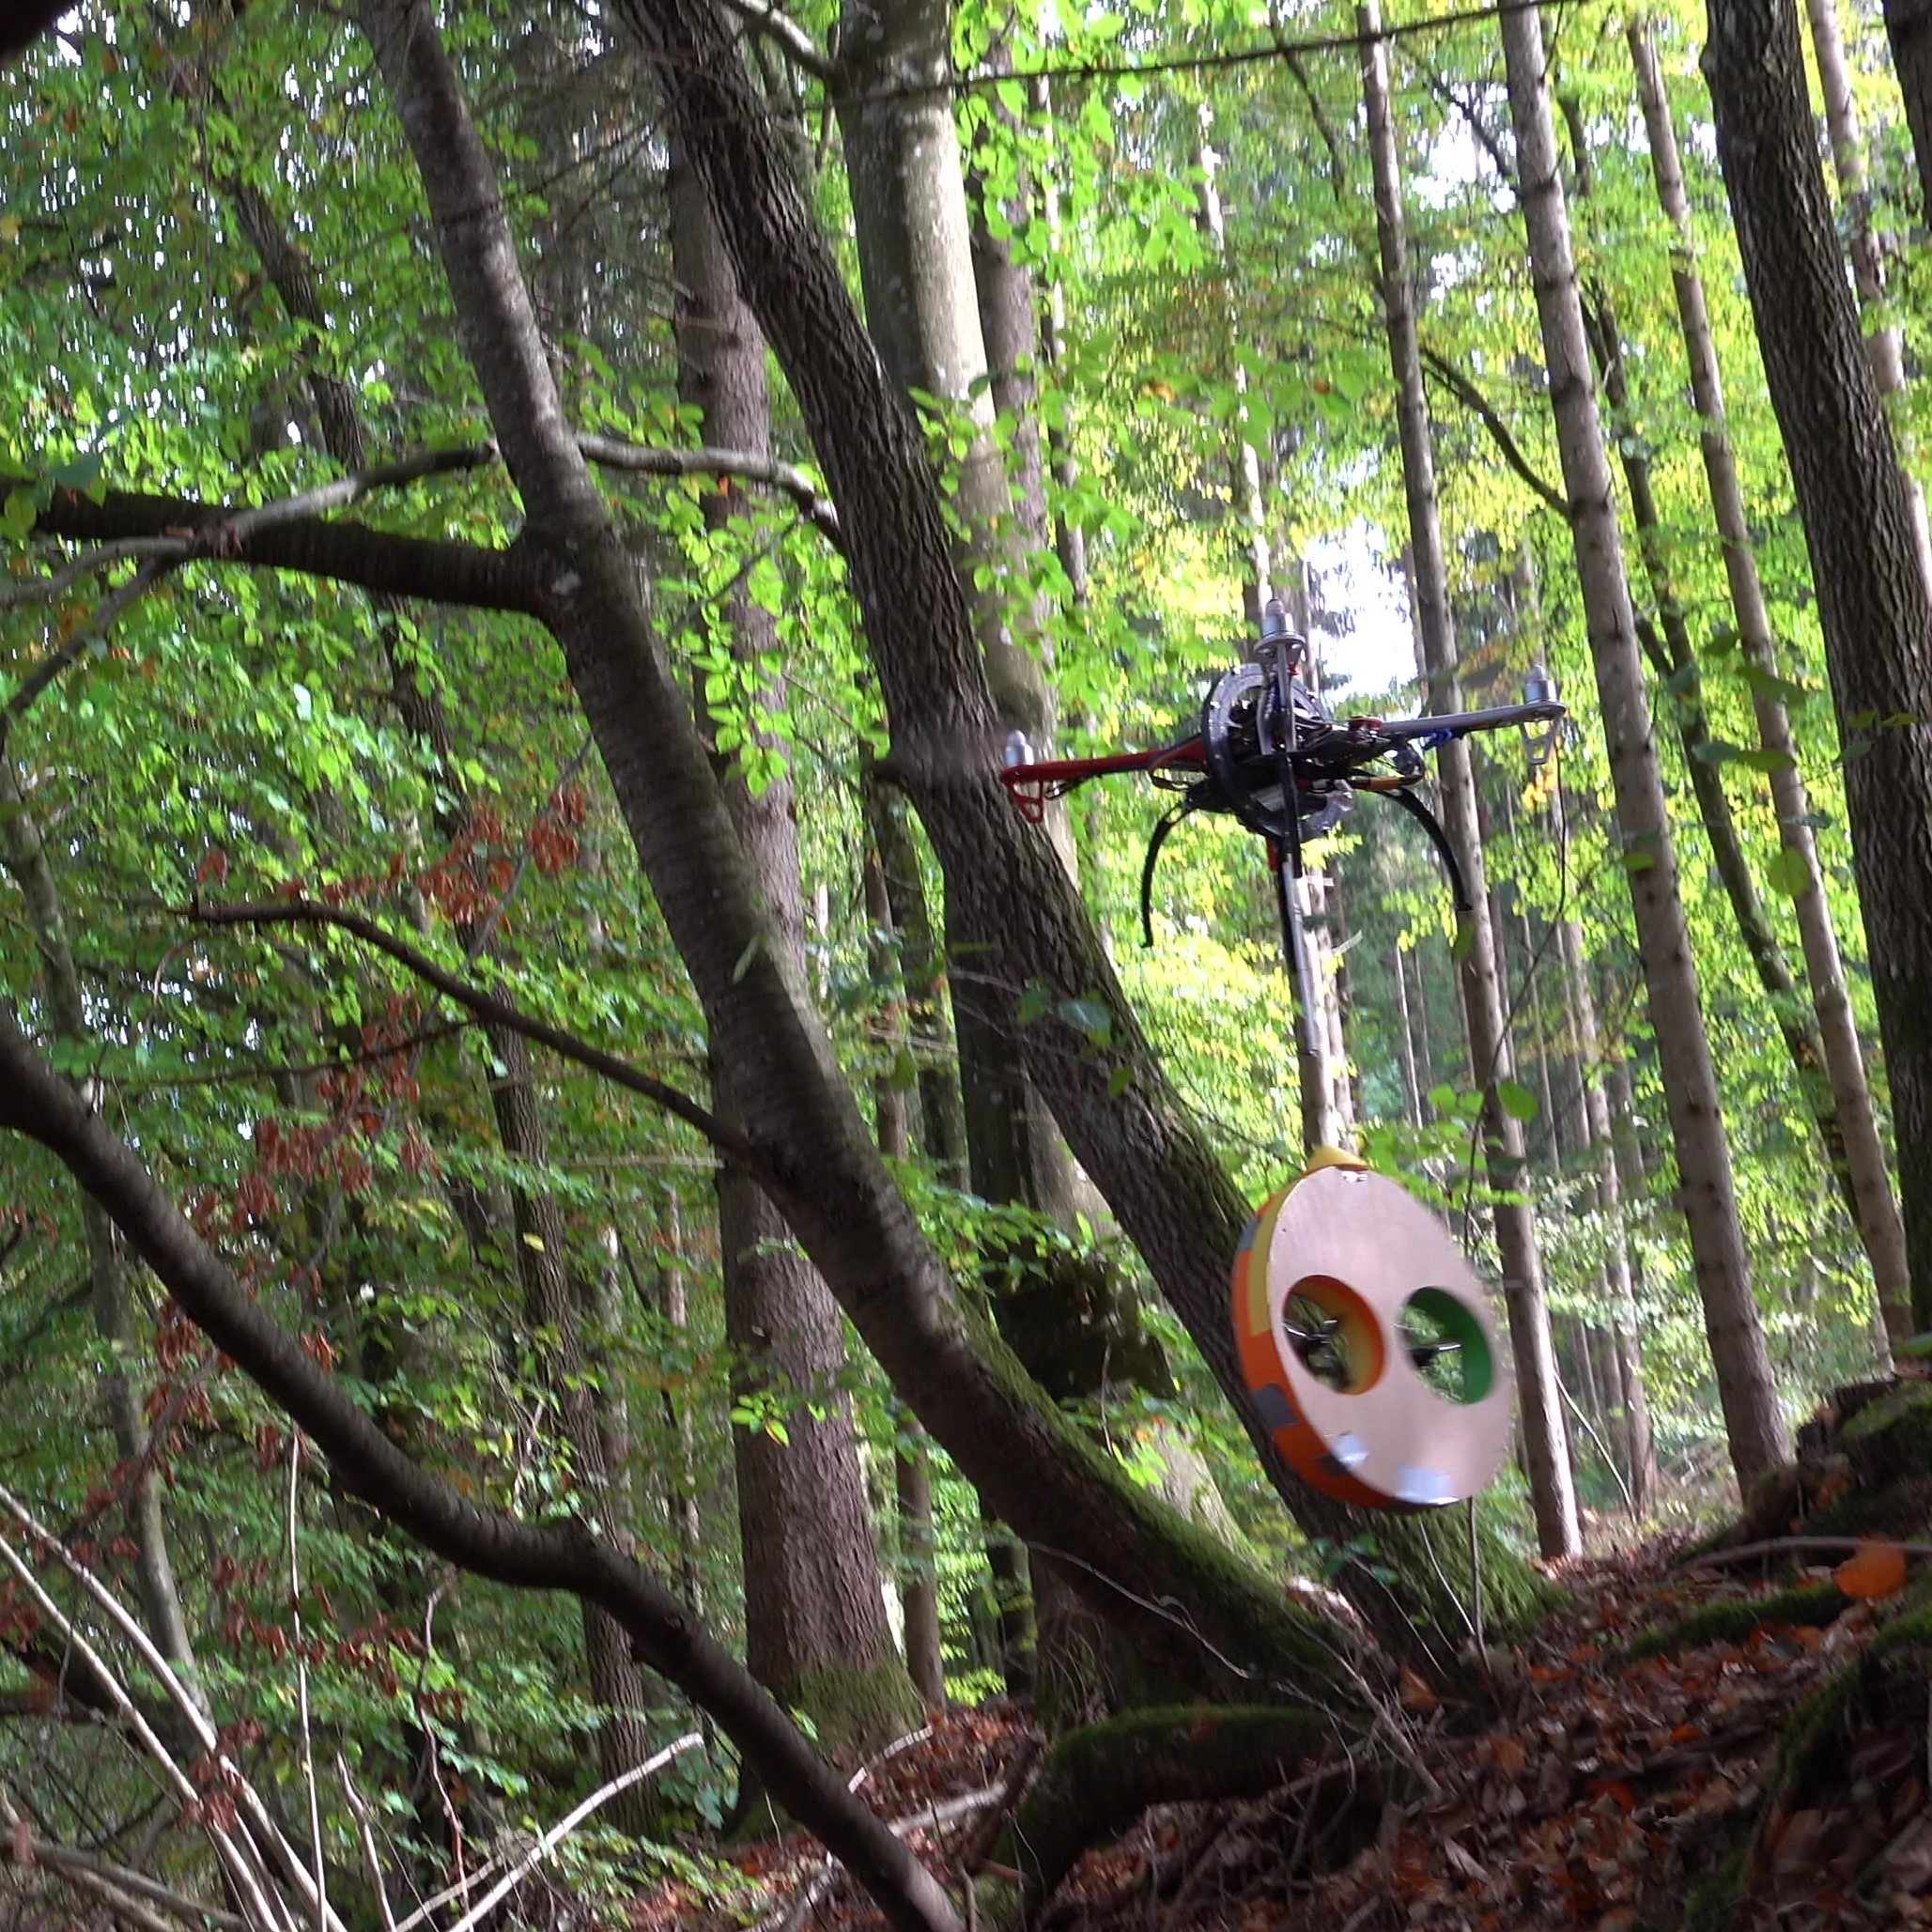
This research, presented at the IEEE International Conference on Robotics and Automation (ICRA) 2024, focuses on developing bio-inspired robots for environmental sensing and monitoring, with a particular emphasis on forest canopy applications. Aerial robots offer exceptional potential for collecting high-resolution spatial and temporal data, but their operational scope is limited by flight endurance. Drawing inspiration from natural perching behaviors, I have designed a multi-modal aerial system that integrates energy-saving tensile perching with an actuated pod for efficient data collection. The system employs a quadrotor drone, a 360° slewing ring tether mechanism, and a streamlined pod equipped with ducted propellers for mobility and branch interaction. By leveraging innovative perching and disentangling strategies, the system achieves significant energy savings, enabling prolonged monitoring missions while expanding the functional capabilities of aerial robots in complex environments.